Motion-Tracked Third Arm
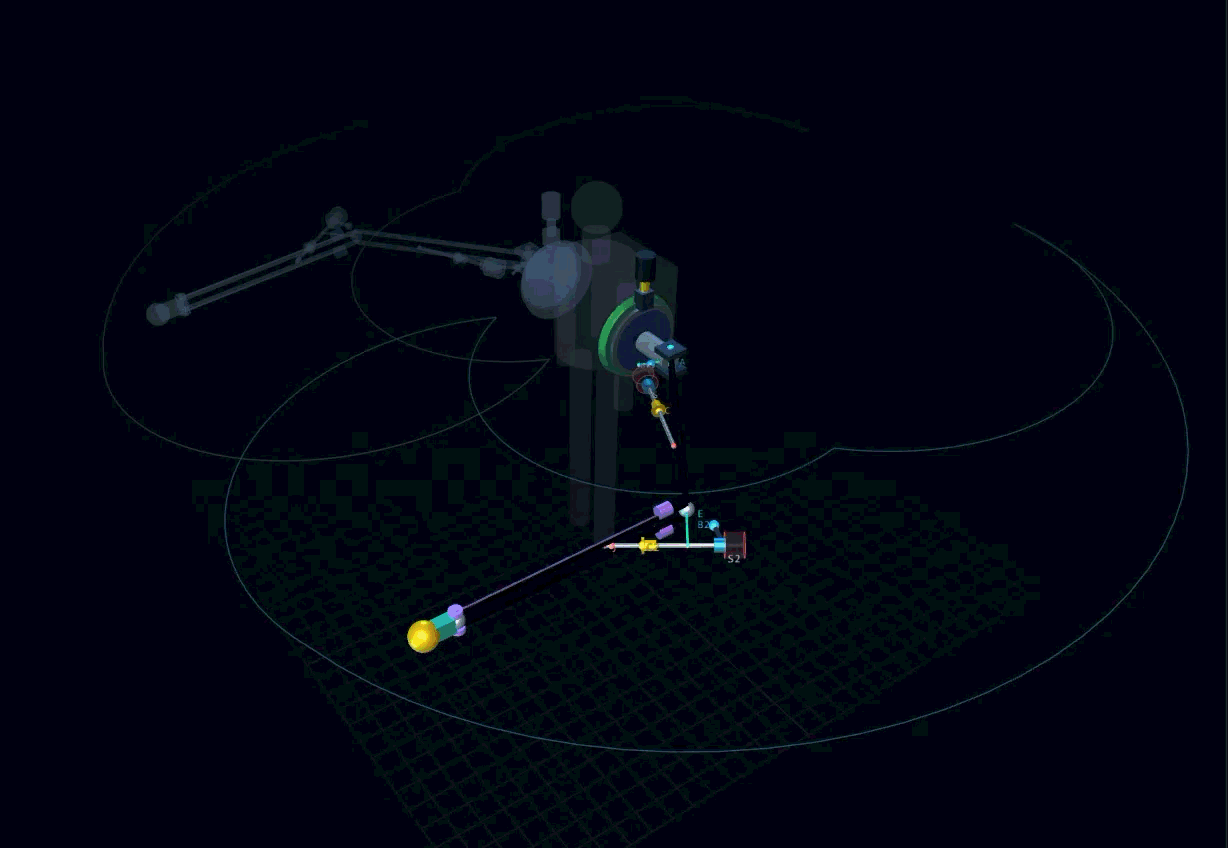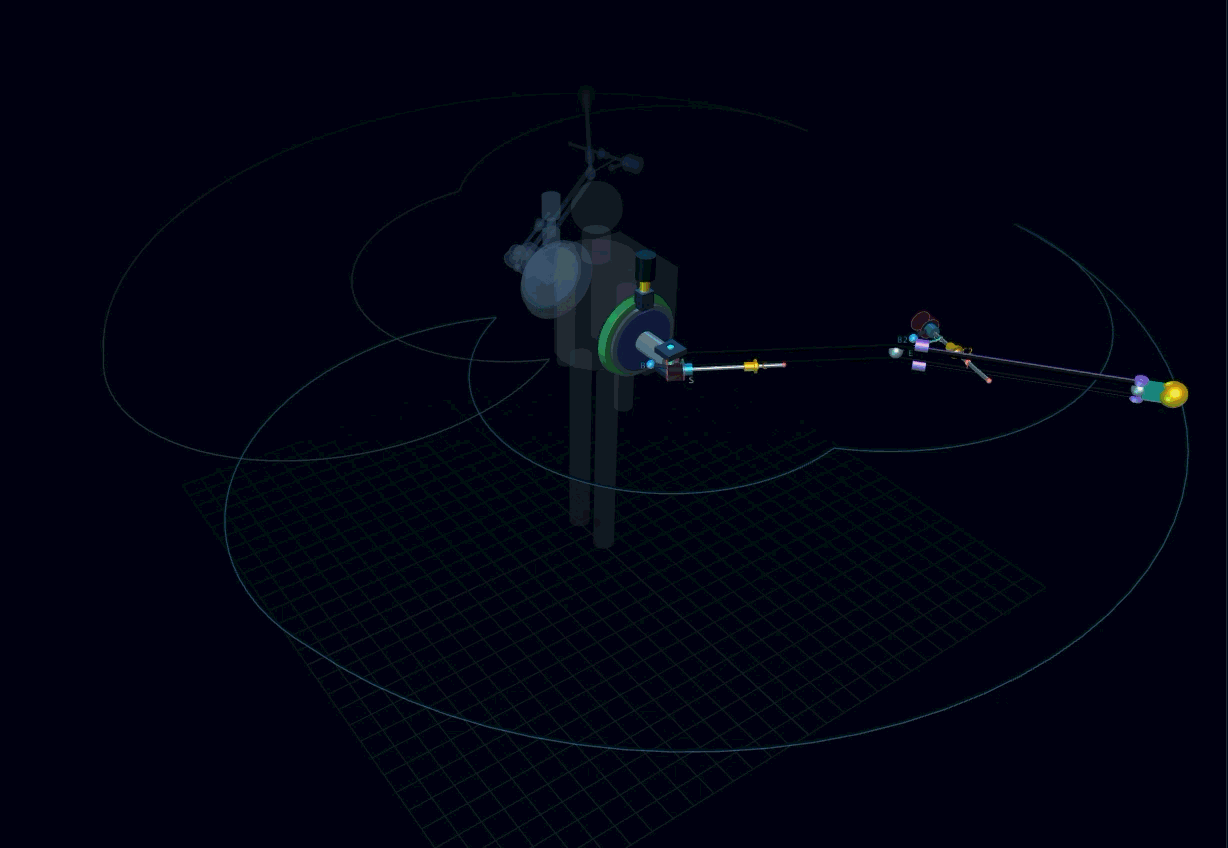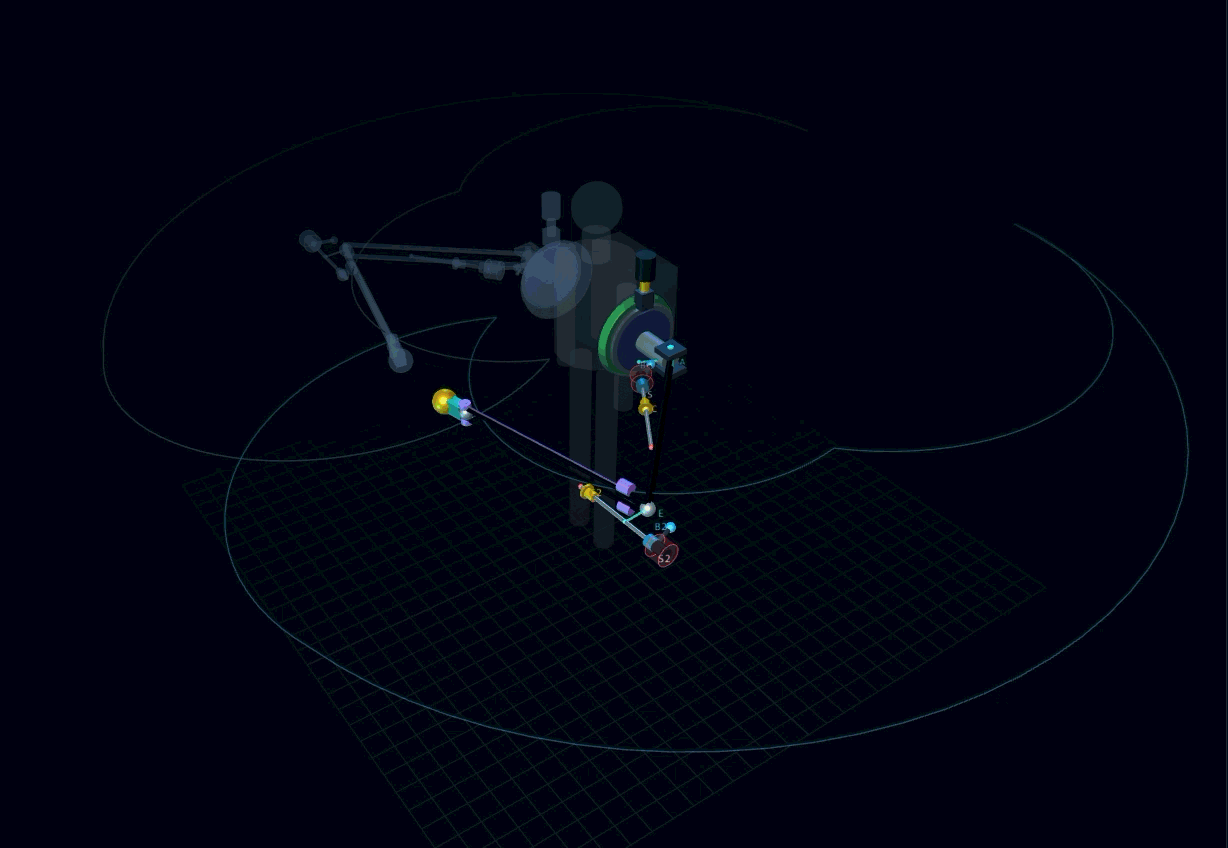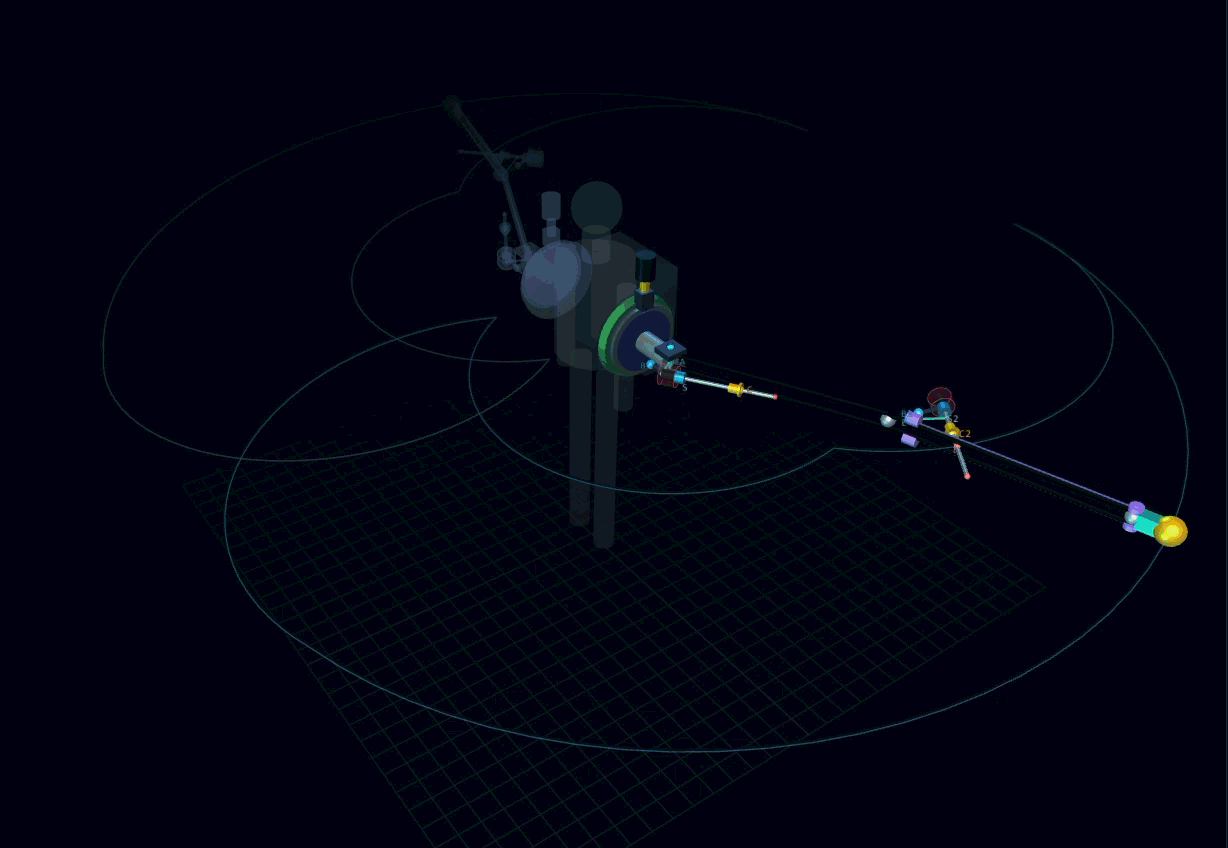
A 6.85 kg, backpack-mounted, 5-axis robotic arm that copies my arm's motion in real time. I demonstrated it live, worn and working, at the UTK Engineering Expo in September 2026. In the video I'm walking around with it on.
- Status
- Wearable prototype, demoed live at the UTK Engineering Expo (Sept 2026)
- Hardware
- 5 brushless motors on FOC controllers and a CAN bus, 36 V packs I built, 4 IMU trackers
- Tools
- Fusion 360, carbon fiber, 3D printing
- Skills
- Mechanism design, motor control, wearable robotics
The problem
I wanted an extra arm that moves the way I move, with no joystick. That means reading where my own arm is, turning that into joint angles for an arm shaped nothing like mine, and doing it fast and safely on a machine strapped to my back.
The build
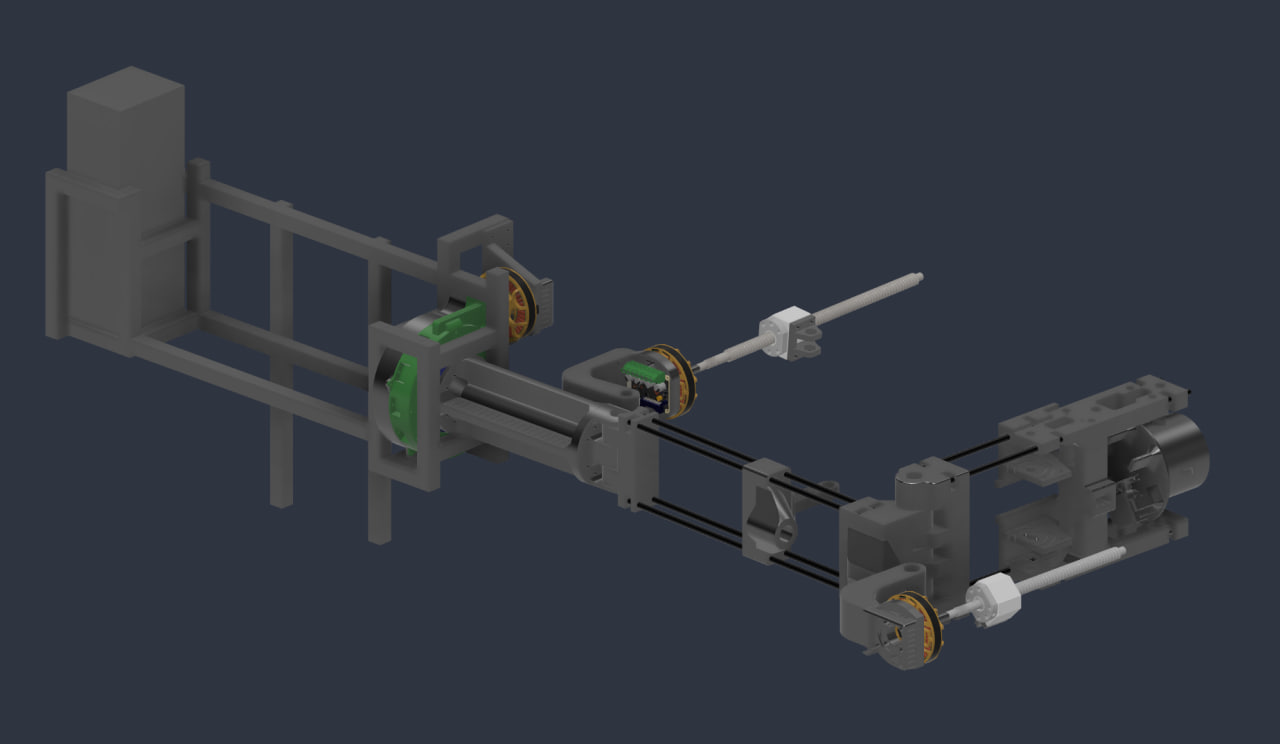
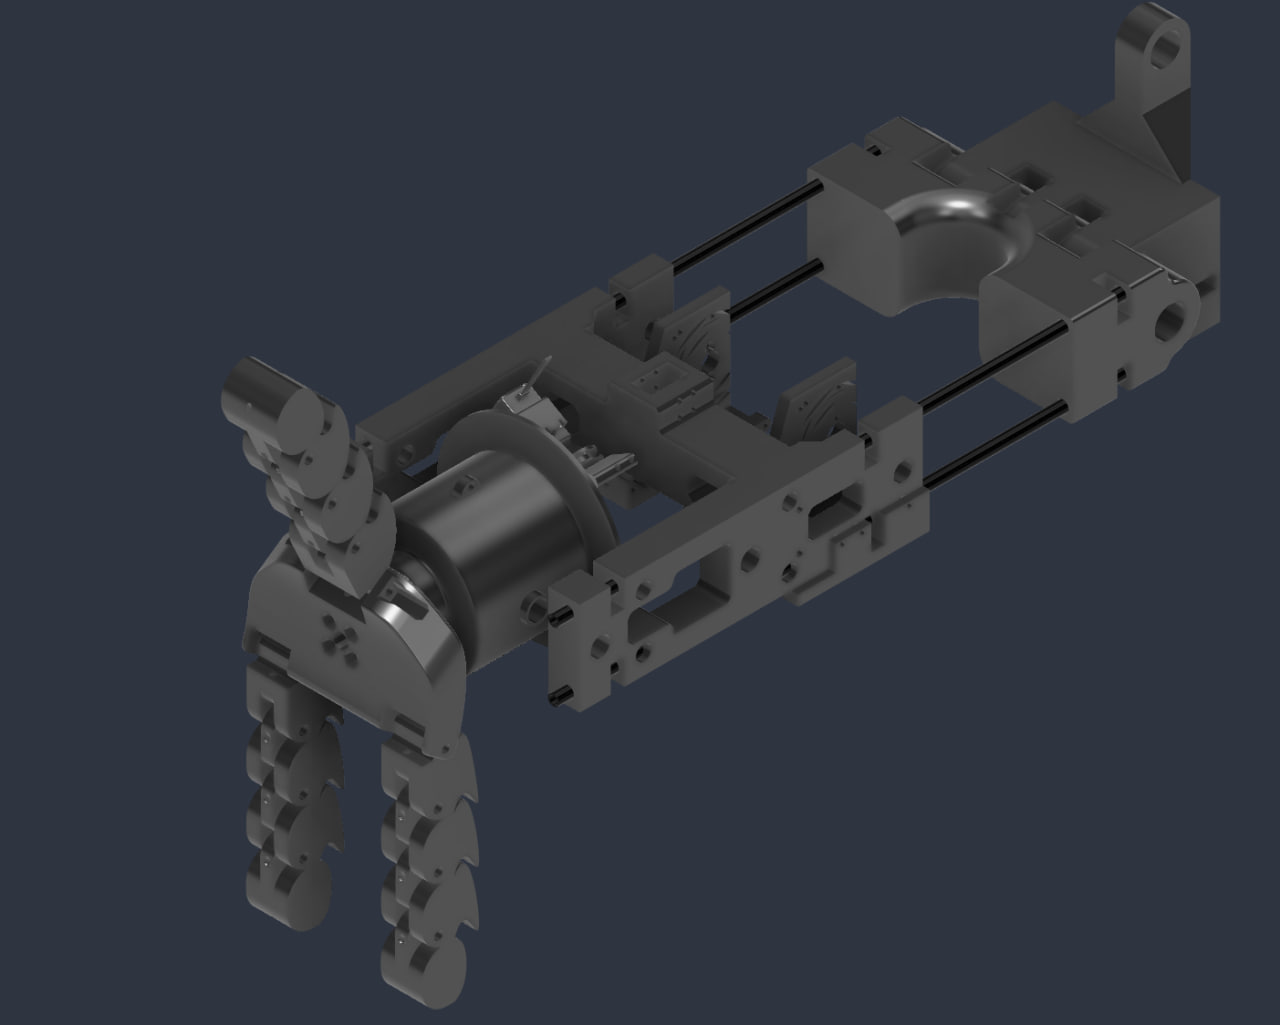
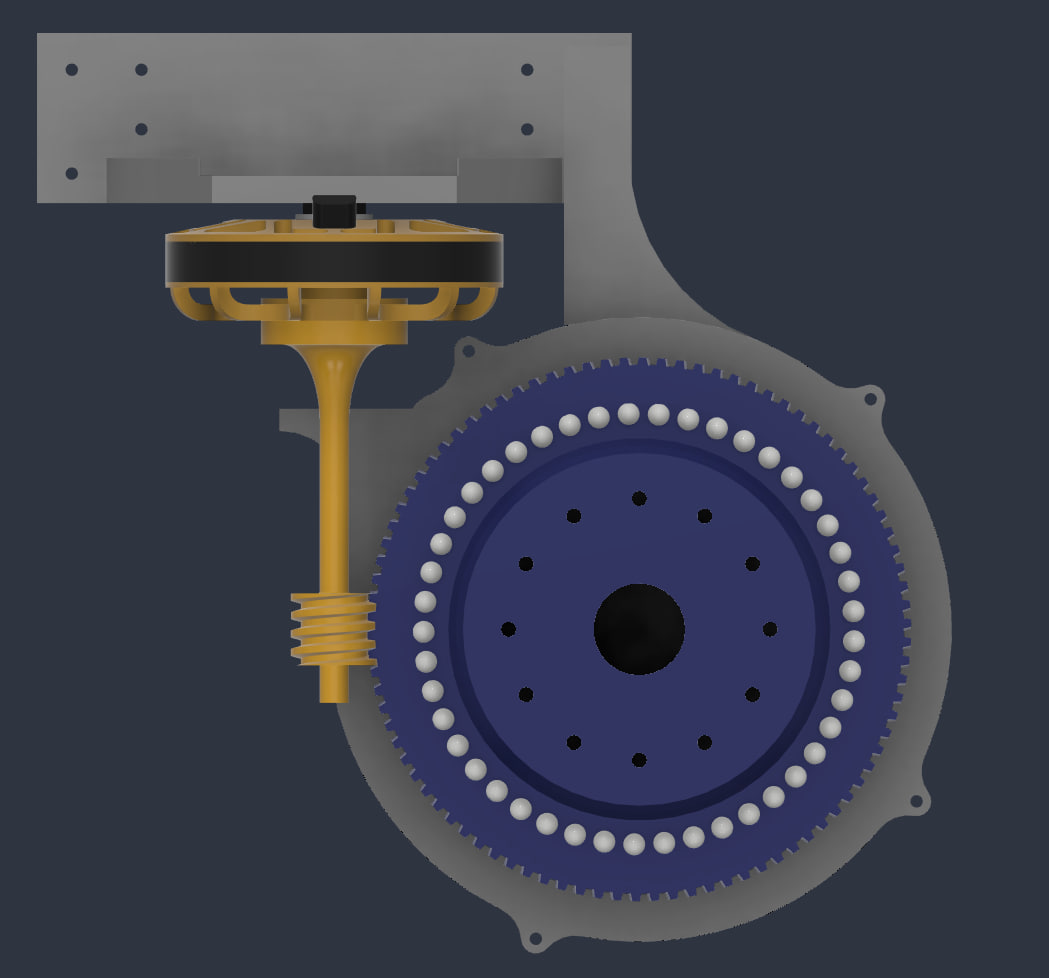
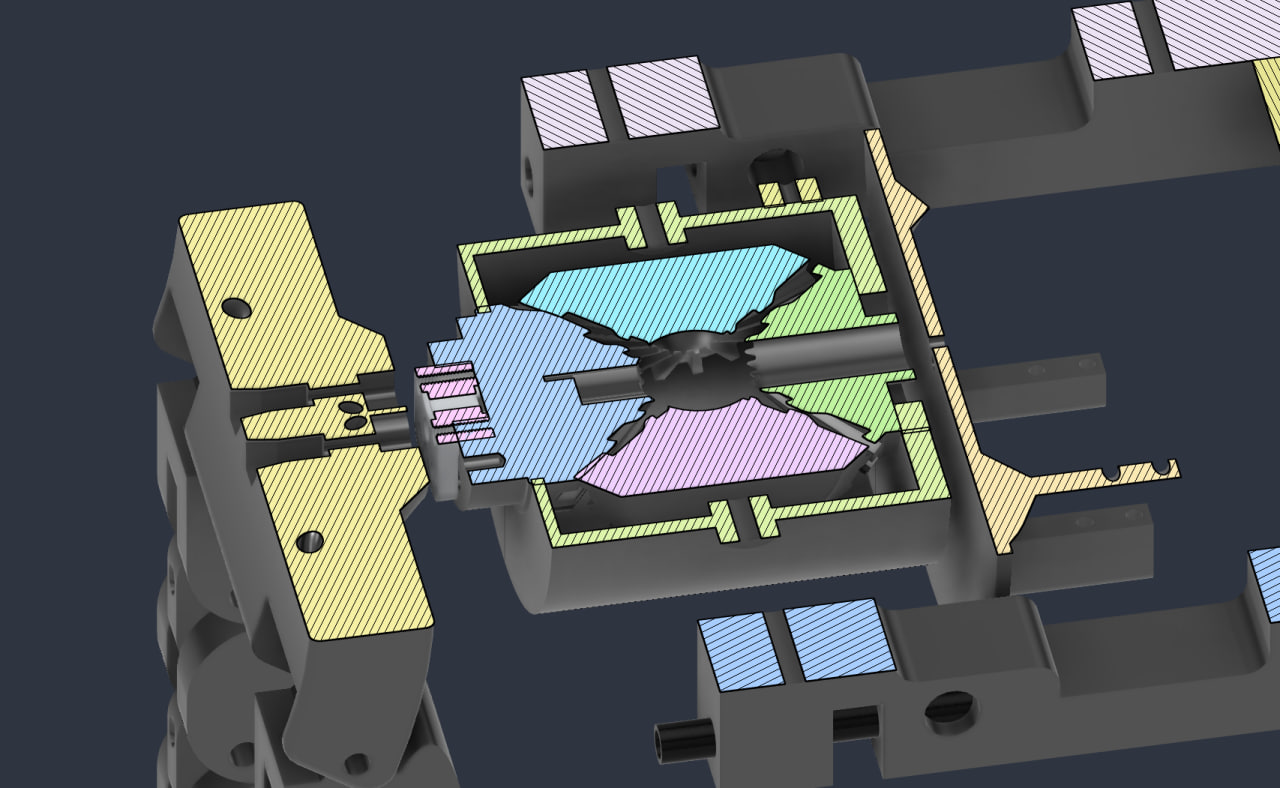
An excavator-style arm: a worm drive at the base, ball screws driving the boom and elbow, and a two-motor belt and bevel differential wrist. The frame is carbon fiber tubes with aluminum collars, after I found 3D-printed PLA would creep under load. Five brushless motors run on FOC controllers over a shared CAN bus, powered by 36 V packs I built, with a hardware e-stop. Four wireless IMU trackers based on the SlimeVR design read my arm, and a three-finger gripper closes on Dyneema tendons, controlled by pressure sensors in a glove.
What I'm learning
Thirteen days before the expo the base worm drive skipped teeth under load, so I cut both links from 880 to 460 mm and redesigned the worm gear, roughly halving the worst-case joint torque. Replaying recordings of my own arm offline cut the median boom error from 4.3° to 0.7° before the arm ever moved. I directed the control software, written mostly with AI coding tools, and tested every piece on the hardware: layered safety stops, stall detection and overheating protection.
Gallery